

RLX COMPONENTS s.r.o. , Electronic Components Distributor.
RLX COMPONENTS s.r.o. , Electronic Components Distributor.
399.00 € bez DPH
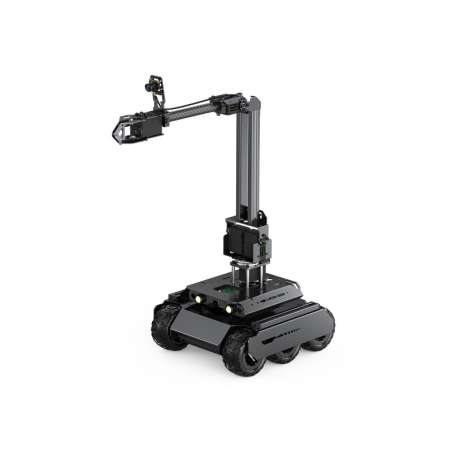
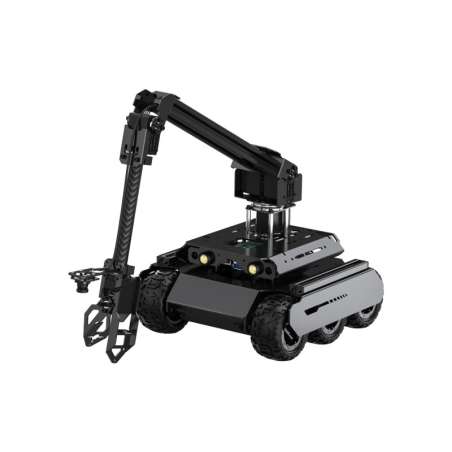
UGV Rover M2 Open-Source 6 Wheels 4WD AI Robot, 4-DOF High-Torque Robotic Arm, Based On ROS 2, Raspberry Pi 5 (WS-35850)
UGV Rover M2 Open-Source 6 Wheels 4WD AI Robot, 4-DOF High-Torque Robotic Arm, Based On ROS 2, Raspberry Pi 5 (WS-35850)
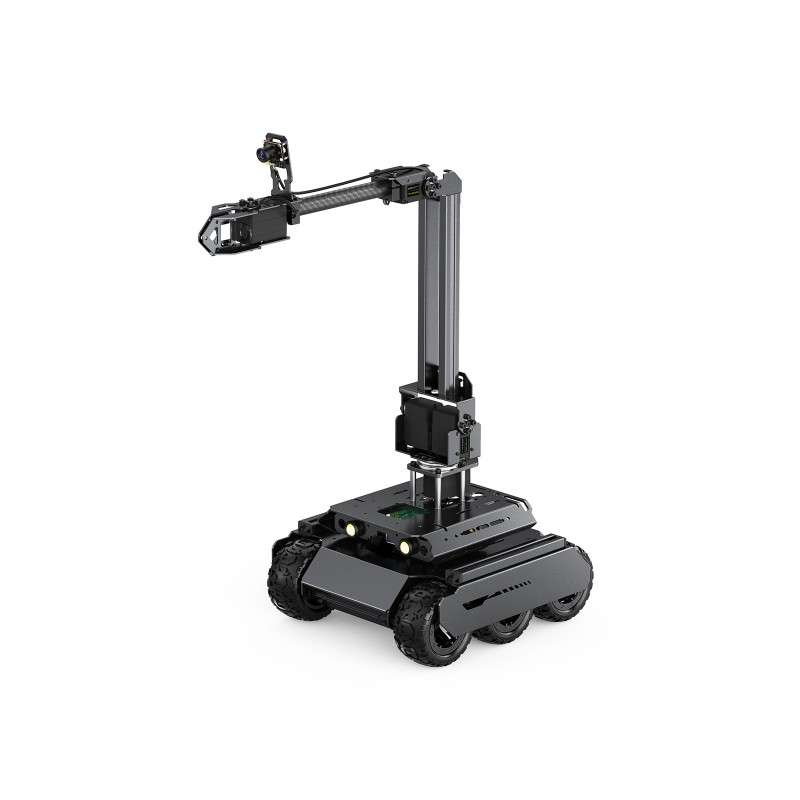
UGV Rover M2 Open-Source 6 Wheels 4WD AI Robot, With 4-DOF High-Torque Robotic Arm, Based On ROS 2, Supports MoveIt And Line-Following Grasping, Suitable For Raspberry Pi 5
The product model name includes: chassis type, module type, host controller model, and function type.
| Model Name | description | Corresponding Module | |
|---|---|---|---|
| Chassis type | UGV Rover | 6 Wheels 4WD chassis |  |
| UGV Beast | Independent suspension off-road tracked chassis |  |
|
| Module type | PT | Equipped with a high-torque 2-axis pan-tilt module |  |
| M2 | Equipped with a high-torque M2 4-DOF robotic arm |  |
|
| Host controller | Jetson Orin | Using Jetson Orin Nano as host controller. Note: the kits with "Acce" at the end of the model name do not include the host controller, and require users to prepare their own Jetson Orin board. |  |
| PI 5 | Using Raspberry Pi 5 as host controller. Note: the kits with "Acce" at the end of the model name do not include the host controller, and require users to prepare their own Raspberry Pi 5 and its heatsink. |  |
|
| PI 4B | Using Raspberry Pi 4B as host controller. Note: the kits with "Acce" at the end of the model name do not include the host controller, and require users to prepare their own Raspberry Pi 4B and its heatsink. | 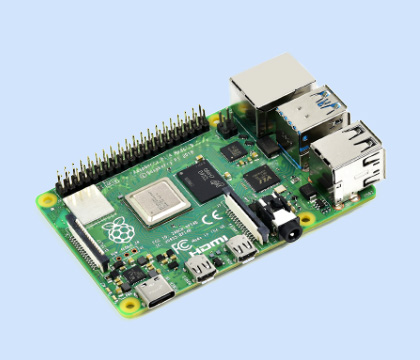 |
|
| Acce | The kits with "Acce" at the end of the model name do not include the host controller, you can choose the Acce Version if you've got a host board. | 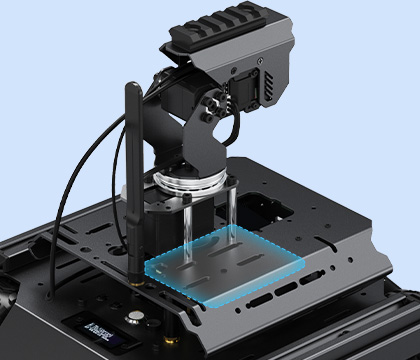 |
|
| Function type | AI Kit | Basic AI kit with a 5MP ultra-wide-angle camera, comes with computer vision functionality and tutorials. |  |
| ROS2 Kit | On the basis of the AI Kit, equipped with a D500 360° Lidar and OAK-D Lite depth camera, comes with the complete ROS2 functionality and tutorials. |  |
|


The UGV Rover M2 Kit is an AI robot designed for mobile grasping, exploration and creation with excellent expansion potential, seamlessly connecting your imagination with reality. Suitable for tech enthusiasts, makers, or beginners in programming, it is your ideal choice for exploring the world of intelligent technology.
The UGV Rover M2 Kit combines a reliable six-wheel, four-wheel-drive mobile chassis with a lightweight 4-DOF robotic arm and a high-performance Raspberry Pi computing core. It can not only reach target locations, but also grasp objects, and transport them, etc, supporting complex strategies and function development while inspiring your creativity. Its dual-controller design combines the high-level AI, vision recognition and task planning of the host controller, with the high-frequency basic operations of the sub controller, making every operation accurate and smooth. With the flexible robotic arm, wide-angle camera, and high-brightness LED lights, the UGV Rover M2 responds effortlessly at your fingertips, delivering a vivid visual experience to every exploration.
In addition, It's easy to be controlled remotely via UGV Rover M2 Kit Web Application without downloading any software, just open your browser and start your journey. Supports high-frame rate real-time video transmission, multiple AI Computer Vision functions and robotic arm mobile grasp projects, the UGV Rover M2 is an ideal platform to realize your ideas and creativity!
Options for host controller (Raspberry Pi 4B / Raspberry Pi 5), or you can choose the Acce Version if you've got a Pi. All kits are equipped with a camera, mounting accessories, TF card, and cooling fan, etc.
| Model | UGV Rover M2 PI4B/PI5 AI KIT | UGV Rover M2 PI4B/PI5 AI KIT Acce |
|---|---|---|
| Picture |  |
 |
| Dimension | 230.42×252.40×521.72mm | |
| Weight | 3100±5g | 3036±5g |
| Chassis height | 25mm | |
| Arm Degrees of Freedom | 3 + 1 (Gripper) | |
| Arm Stall Torque | 30KG.CM | |
| Arm Servo Model | ST3215 Servo | |
| Host controller (IPC) | RPi 4B 4GB | NOT included |
| RPi 5 4GB | ||
| Host System support | Debian Bookworm | |
| ROS 2 Version | ROS2-HUMBLE-LTS | |
| Camera FOV | 175° | |
| Power supply | 3S UPS Module | |
| Batt support | 18650 lithium Batt x 3 (NOT included) | |
| Demo control methods | Web application / JupyterLab interactive programming | |
| Default Max speed | 1.3m/s | |
| Number of Driving wheels | 4 | |
| Number of Support wheels | 6 | |
| Tire diameter | 80mm | |
| Tire width | 42.5mm | |
| Minimum turning radius | 0m (In-situ rotation) | |
Supports Raspberry Pi 5 / Raspberry Pi 4B, offering powerful computing performance for more possibilities

Connecting with Raspberry Pi 4B

Connecting with Raspberry Pi 5
The host controller adopts Raspberry Pi for AI vision and strategy planning, and the sub controller uses ESP32 for motion control and sensor data processing

Ensures both advanced decision-making performance and system compatibility. It supports all the AI functions of the previous AI Kit products, along with ROS 2 basic functions such as vision-guided grasping and multiple remote control methods, opening up more ways to explore

equipped with 5MP 175° Ultra wide-angle camera for capturing every detail

The 360°-Rotating Robotic Arm adopts high-torque bus servos with excellent expansion potential, providing a better control experience as FPS games.

Equipped with a camera as its “eyes,” the robot can follow a ground guide line while detecting and picking up small blocks during movement. When a target is detected, the robotic arm precisely extends and grasps the block, seamlessly combining line following and vision-based object picking in one smooth demonstration

Provides Gazebo robot mode and complete functionality library for
simulation debugging, helping you verify and test the system
during the early stages of development

High-brightness LED light for Ensuring Clear Images In Low-Light Conditions

Comes with 2 × 10²⁰ European standard profile rails, and supports installing additional peripherals via the boat nuts to meet different needs, easily expanding the special operation scenarios

Note: Only the rail, boat nuts, and M4 screws are included, other accessories should be purchased separately.
6 wheels × 4WD design, using 6 wheels can provide a more stable platform and larger contact area, while 4WD can provide stronger power and traction to deal with various terrains and obstacles

Can be used to install a variety of peripherals, including D500 Lidar, STL-27L Lidar, camera, or other modules. Open source for DXF drawing and 3D model, which is more convenient for secondary development

No App installation required, allows users to connect and control the robot via mobile phones, tablets and computers via browser Web App. Supports shortcut key control such as arrow keys and the mouse via a PC with keyboard

The 3D digital twin view and data panel on the web interface update in sync, making the motion status clear at a glance for easier remote control

Adopts Flask lightweight web application, based on WebRTC ultra-low latency real-time transmission, using Python language and easy to extend, working seamlessly with OpenCV

based on OpenCV to achieve color recognition and automatic Targeting
based on OpenCV to achieve Face recognition, supports automatic photo taking or video recording once a face is recognized

supports recognizing many common objects with the default model

Combines OpenCV and MediaPipe to realize gesture control of LED and interact seamlessly with AI
Gesture control for photo taking
LED ON/OFF control
MediaPipe is an open-source framework developed by Google for building cross-platform multimedia processing pipelines, provides a set of pre-built components and tools, its high-performance processing capability enables the robot to respond to and process complex multimedia inputs such as real-time video analytics

Face Recognition

Attitude Detection
Integrated with Vision line tracking function on the Computer Vision demo, comes with yellow tape for easier planning a path for the robot. Users can understand the basic algorithms of autonomous driving with this simple demo

Reserved space on the mounting plate with M2.5 mounting holes, for installing D500 / STL27L Lidar or other peripherals

* Comes with screws and cables for installing the D500 LIDAR, please refer to documentation for more details. The D500 LIDAR and Batt set are NOT included.
The robot only occupies the UART interface of the Raspberry Pi GPIO for communication, adapting outer side 40PIN header of the driver board for expanding more peripherals and functions

Equipped with audio driver board, Dual-track speaker, and onboard microphone, built in 3.5mm audio jack for connecting peripherals to achieve text-to-speech and audio playing

Real-time monitoring the operating status of the robot

Quick to set up, easy to expand
Easily customize and add new functions without Modifying front-end code

Based on ESP-NOW communication protocol, multiple robots can communicate with each other without IP or MAC address, achieving multi-device collaboration with 100-microsecond low-latency communication

Comes with a wireless gamepad, making robot control more flexible. Connect the USB receiver to a computer for remote operation over the network, or directly to the robot for short-range wireless control. Provides open source demo for customizing your own interaction method

Supports installing 4G/5G module* for the application scenarios without WiFi

* You may need to use Tunneling Service such as Ngrok, Cpolar, or LocalTunnel to expose the local network service of the robot (Flask application) to the Internet so that you can control the robot from anywhere.

* Provides the usage tutorials of Ngrok only, we do not provide any Ngrok accounts or Servers. You can follow our tutorial to open your own Ngrok service, or choose other tunneling services according to your needs.
supports accessing JupyterLab via devices such as mobile phones and tablets to read the tutorials and edit the code on the web page, making development easier
We Provide Complete Tutorials And demos To Help Users Get Started Quickly For Learning and Secondary Development


Onboard high-efficiency UPS module, supports charging and discharging at the same time to ensure continuous standby time
* the 18650 batt is NOT included


The sub controller performs high-frequency PID closed-loop speed control, supports quick response and accurate speed control, with High-speed motors, up to 0.5m/s


Automatically creates a hotspot for accessing when there is no available network connection after powering on

Built in high-efficient active cooling for long-time operation of the host controller even when compiling complex ROS2 packages

OLED display for real-time information displaying

Supports expanding external Batt set via DC5521 port


Balenie Obsahuje / Package Content

Špecifické referencie
UGV Rover M2 Open-Source 6 Wheels 4WD AI Robot, 4-DOF High-Torque Robotic Arm, Based On ROS 2, Raspberry Pi 5 (WS-35850)
399.00 € bez DPH